| Specification | ||||
|---|---|---|---|---|
| Basic Info | ||||
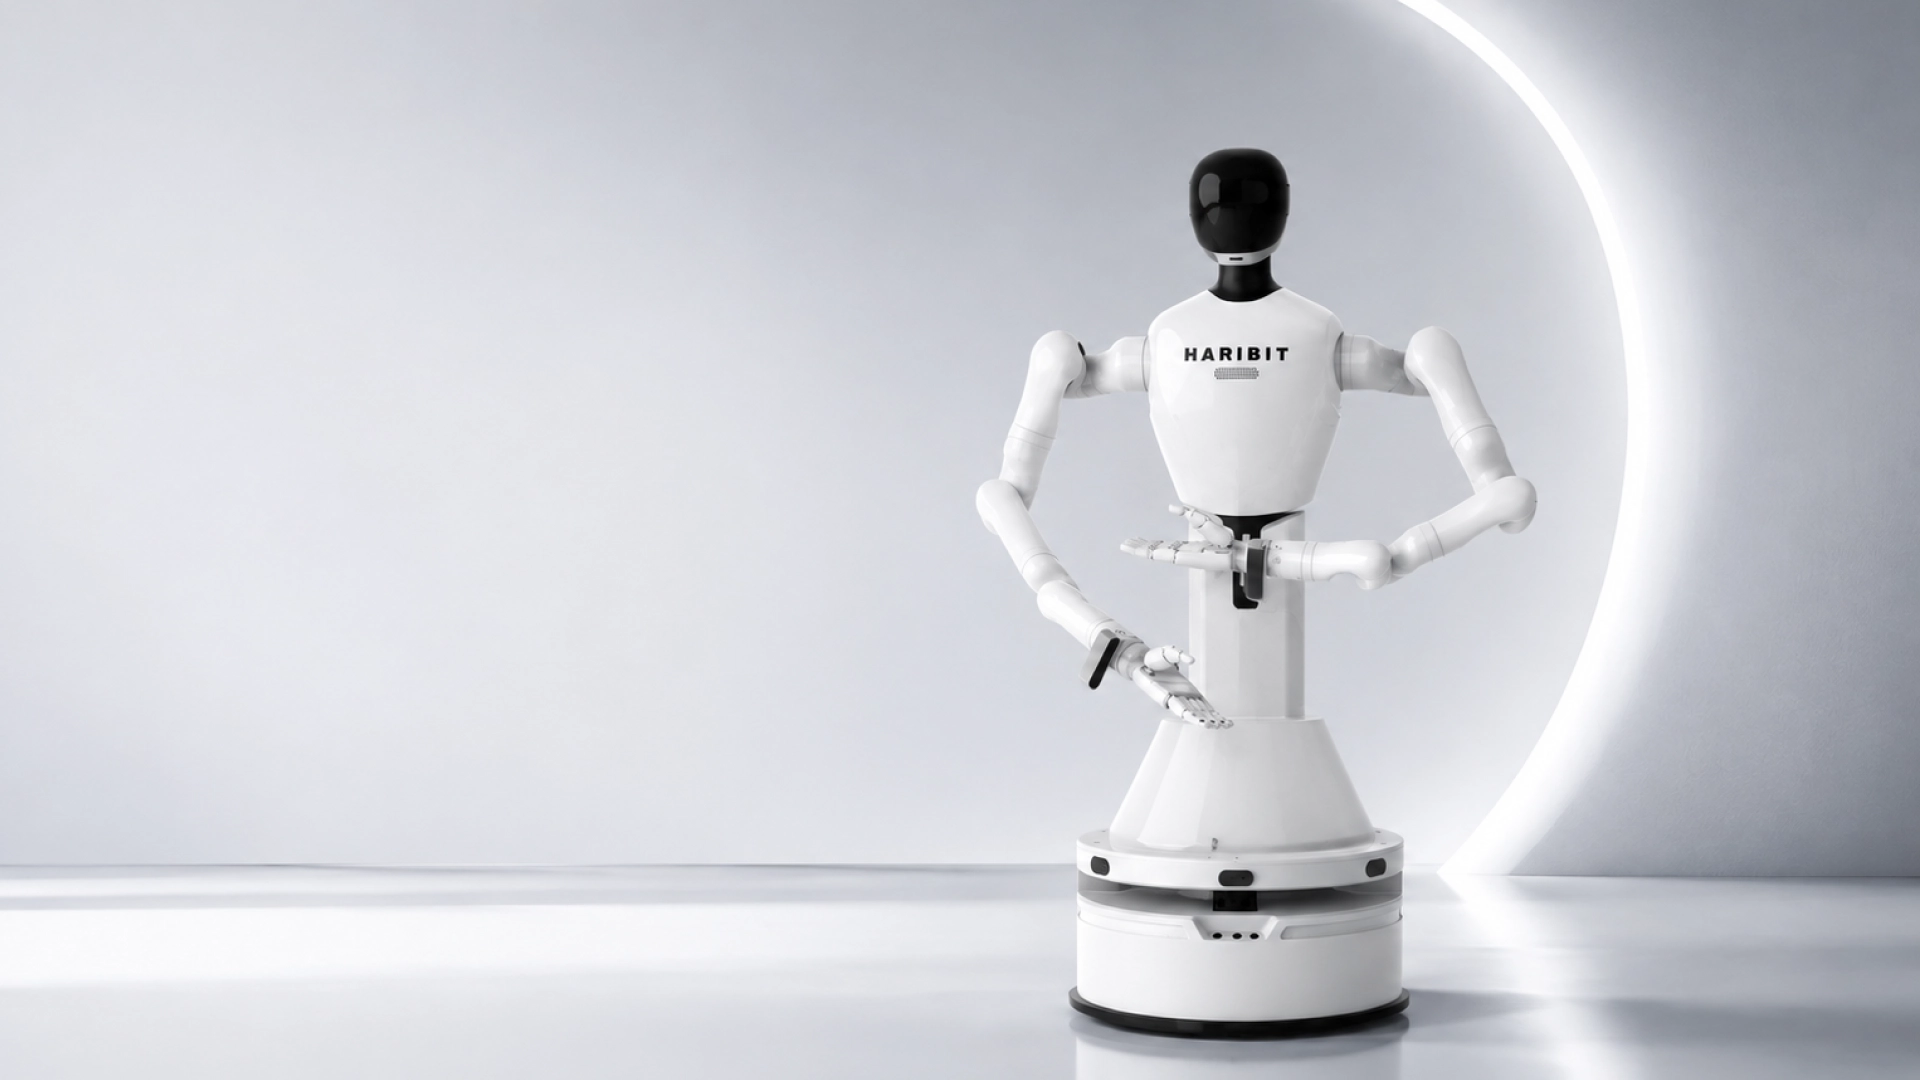
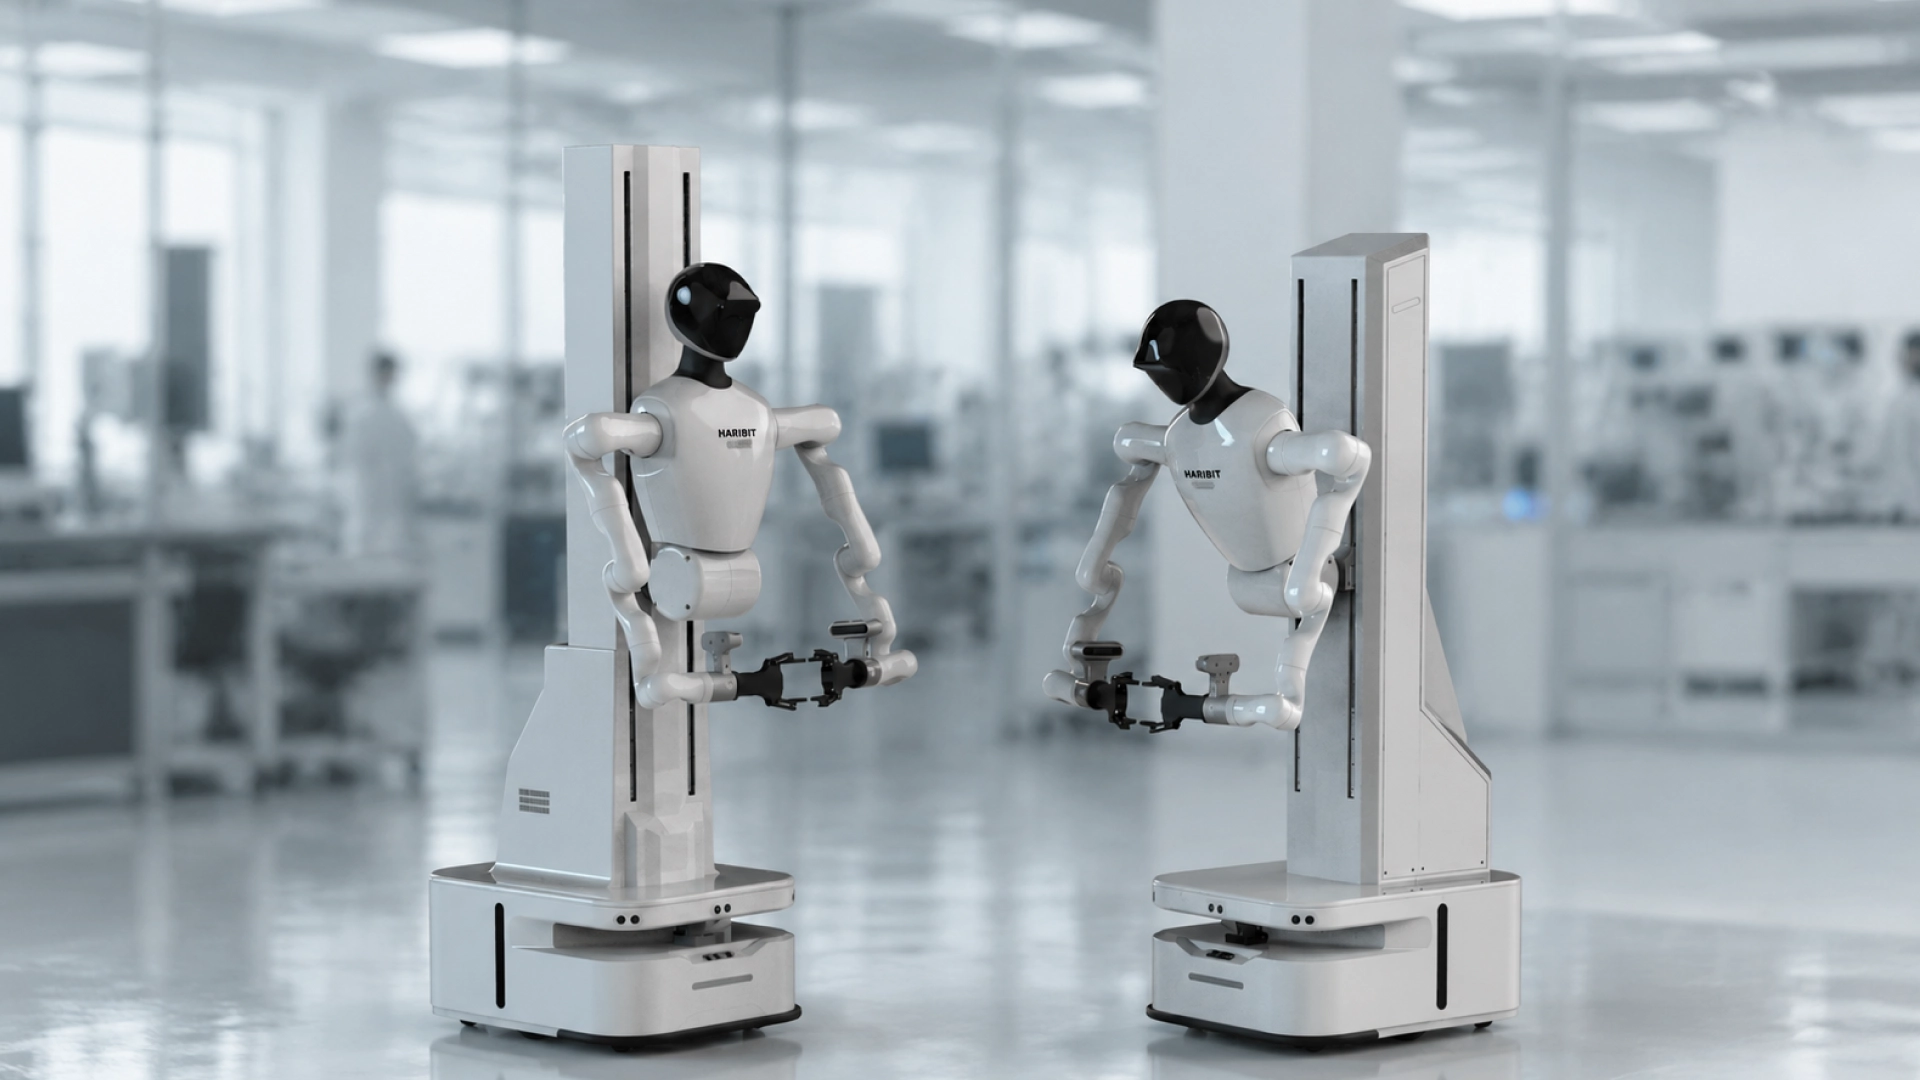
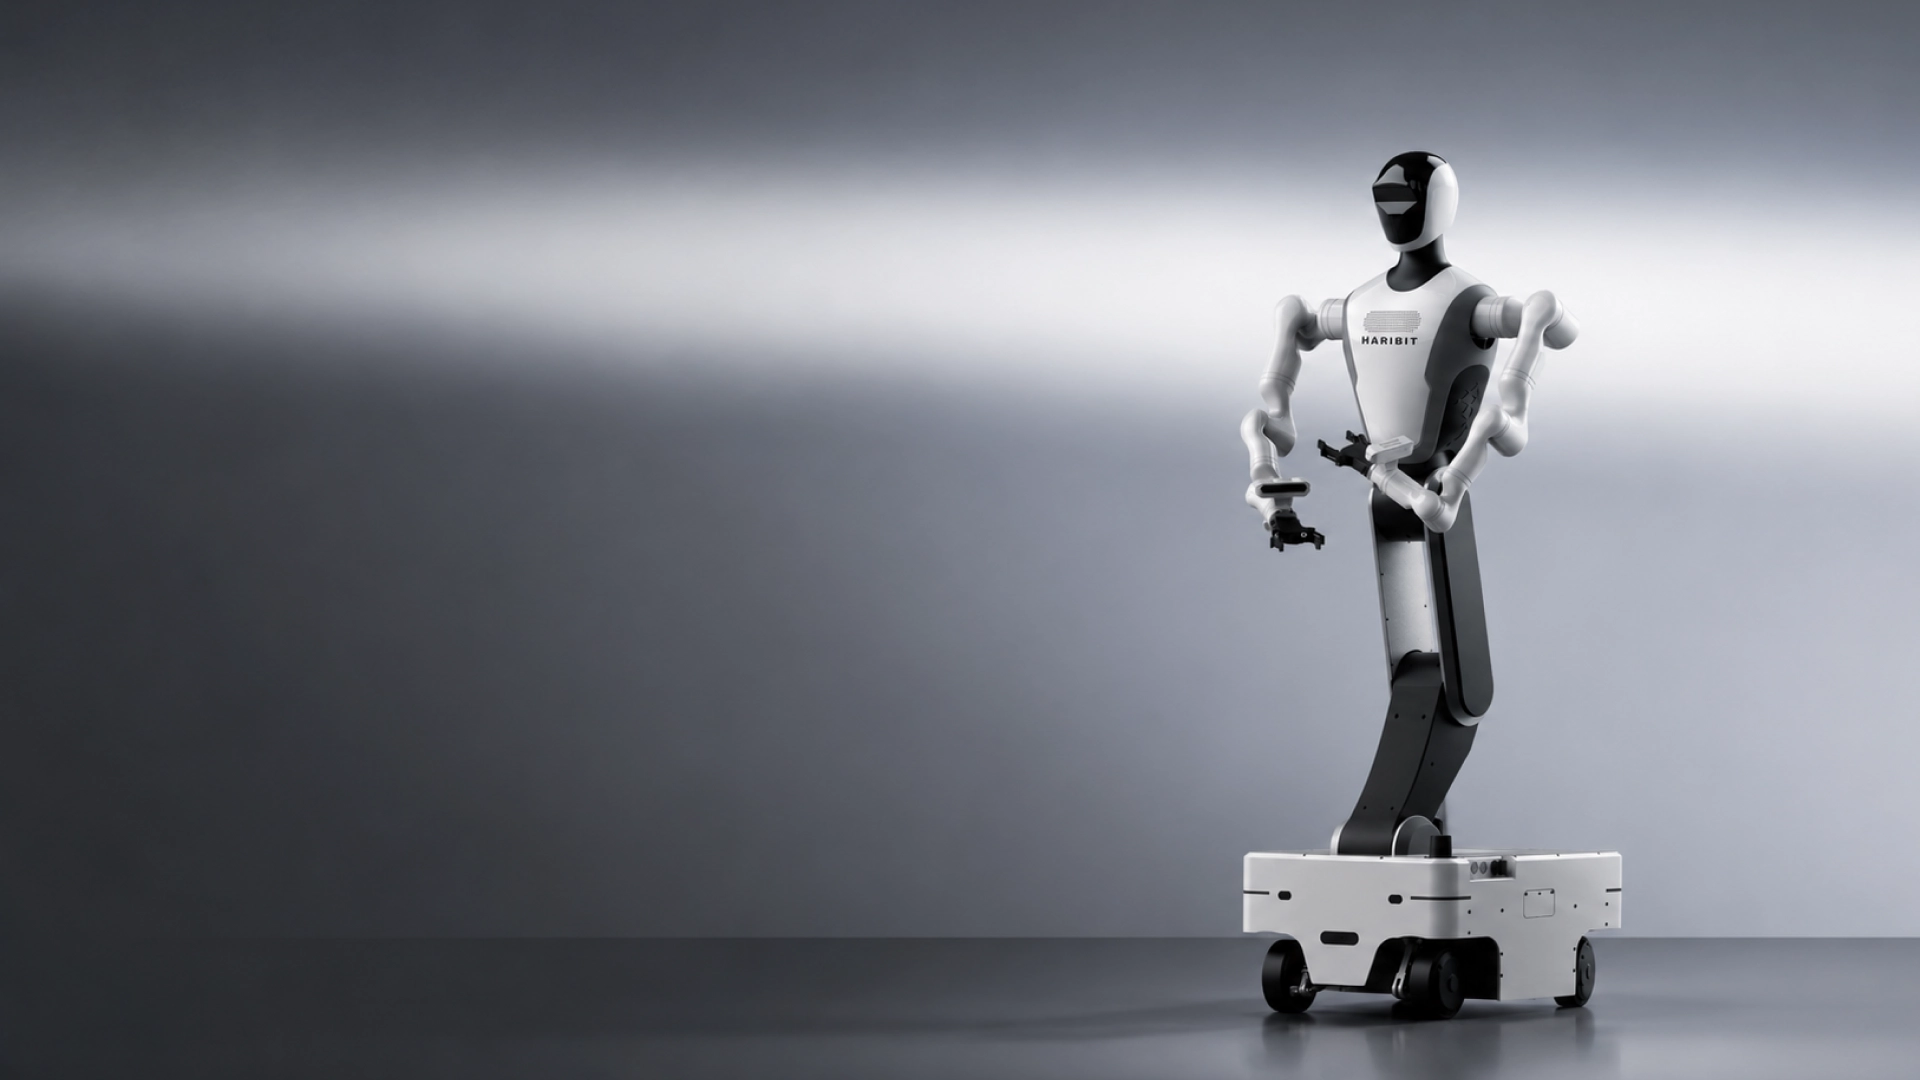
| Name | SR02 | HARIBIT Dual-Arm Composite Robot | HARIBIT LHC-RW2-LW-6G | HARIBIT LHC-RW2-F-6G |
| Company | Beijing Institute of Technology Harbit | Beijing Institute of Technology Harbit | Beijing Institute of Technology Harbit | Beijing Institute of Technology Harbit |
| Release Year | 2024 | 2026 | 2026 | 2026 |
| Stage | Demo | Mass Production | Mass Production | Mass Production |
| Locomotion | Biped | Wheeled | Wheeled | Wheeled |
| Physical Specs | ||||
| Height (cm) | 145 | 150 | 172 | 121 |
| Weight (kg) | 45 | 85 | 145 | 132 |
| Total DOF | 24 | - | - | 34 |
| Hand DOF | - | - | - | - |
| Performance | ||||
| Max Speed (km/h) | - | 4.3 | 4.3 | 5.4 |
| Dual-Arm Payload (kg) | - | 10 | 10 | 10 |
| Battery (h) | 3.5 | 4 | 4.5 | - |
| Computing Platform | Intel Core i5 | 100 TOPS onboard compute (controller: 16 GB RAM / 256 GB storage) | 275 TOPS onboard compute (controller: 64 GB RAM / 1 TB storage) | 275 TOPS onboard compute (controller: 64 GB RAM / 1 TB storage), supports local inference of 7B-scale models |
| Sensors | LiDAR-vision fusion, 1 depth camera | SLAM LiDAR for autonomous navigation; laser scanning obstacle avoidance | SLAM LiDAR for autonomous navigation and mapping; laser scanning obstacle avoidance | SLAM LiDAR for autonomous navigation; laser scanning obstacle avoidance; collision detection; multimodal safety perception |
| Commercial | ||||
| Price | - | - | - | - |