Back to Jiangsu Yunmu Intelligent Manufacturing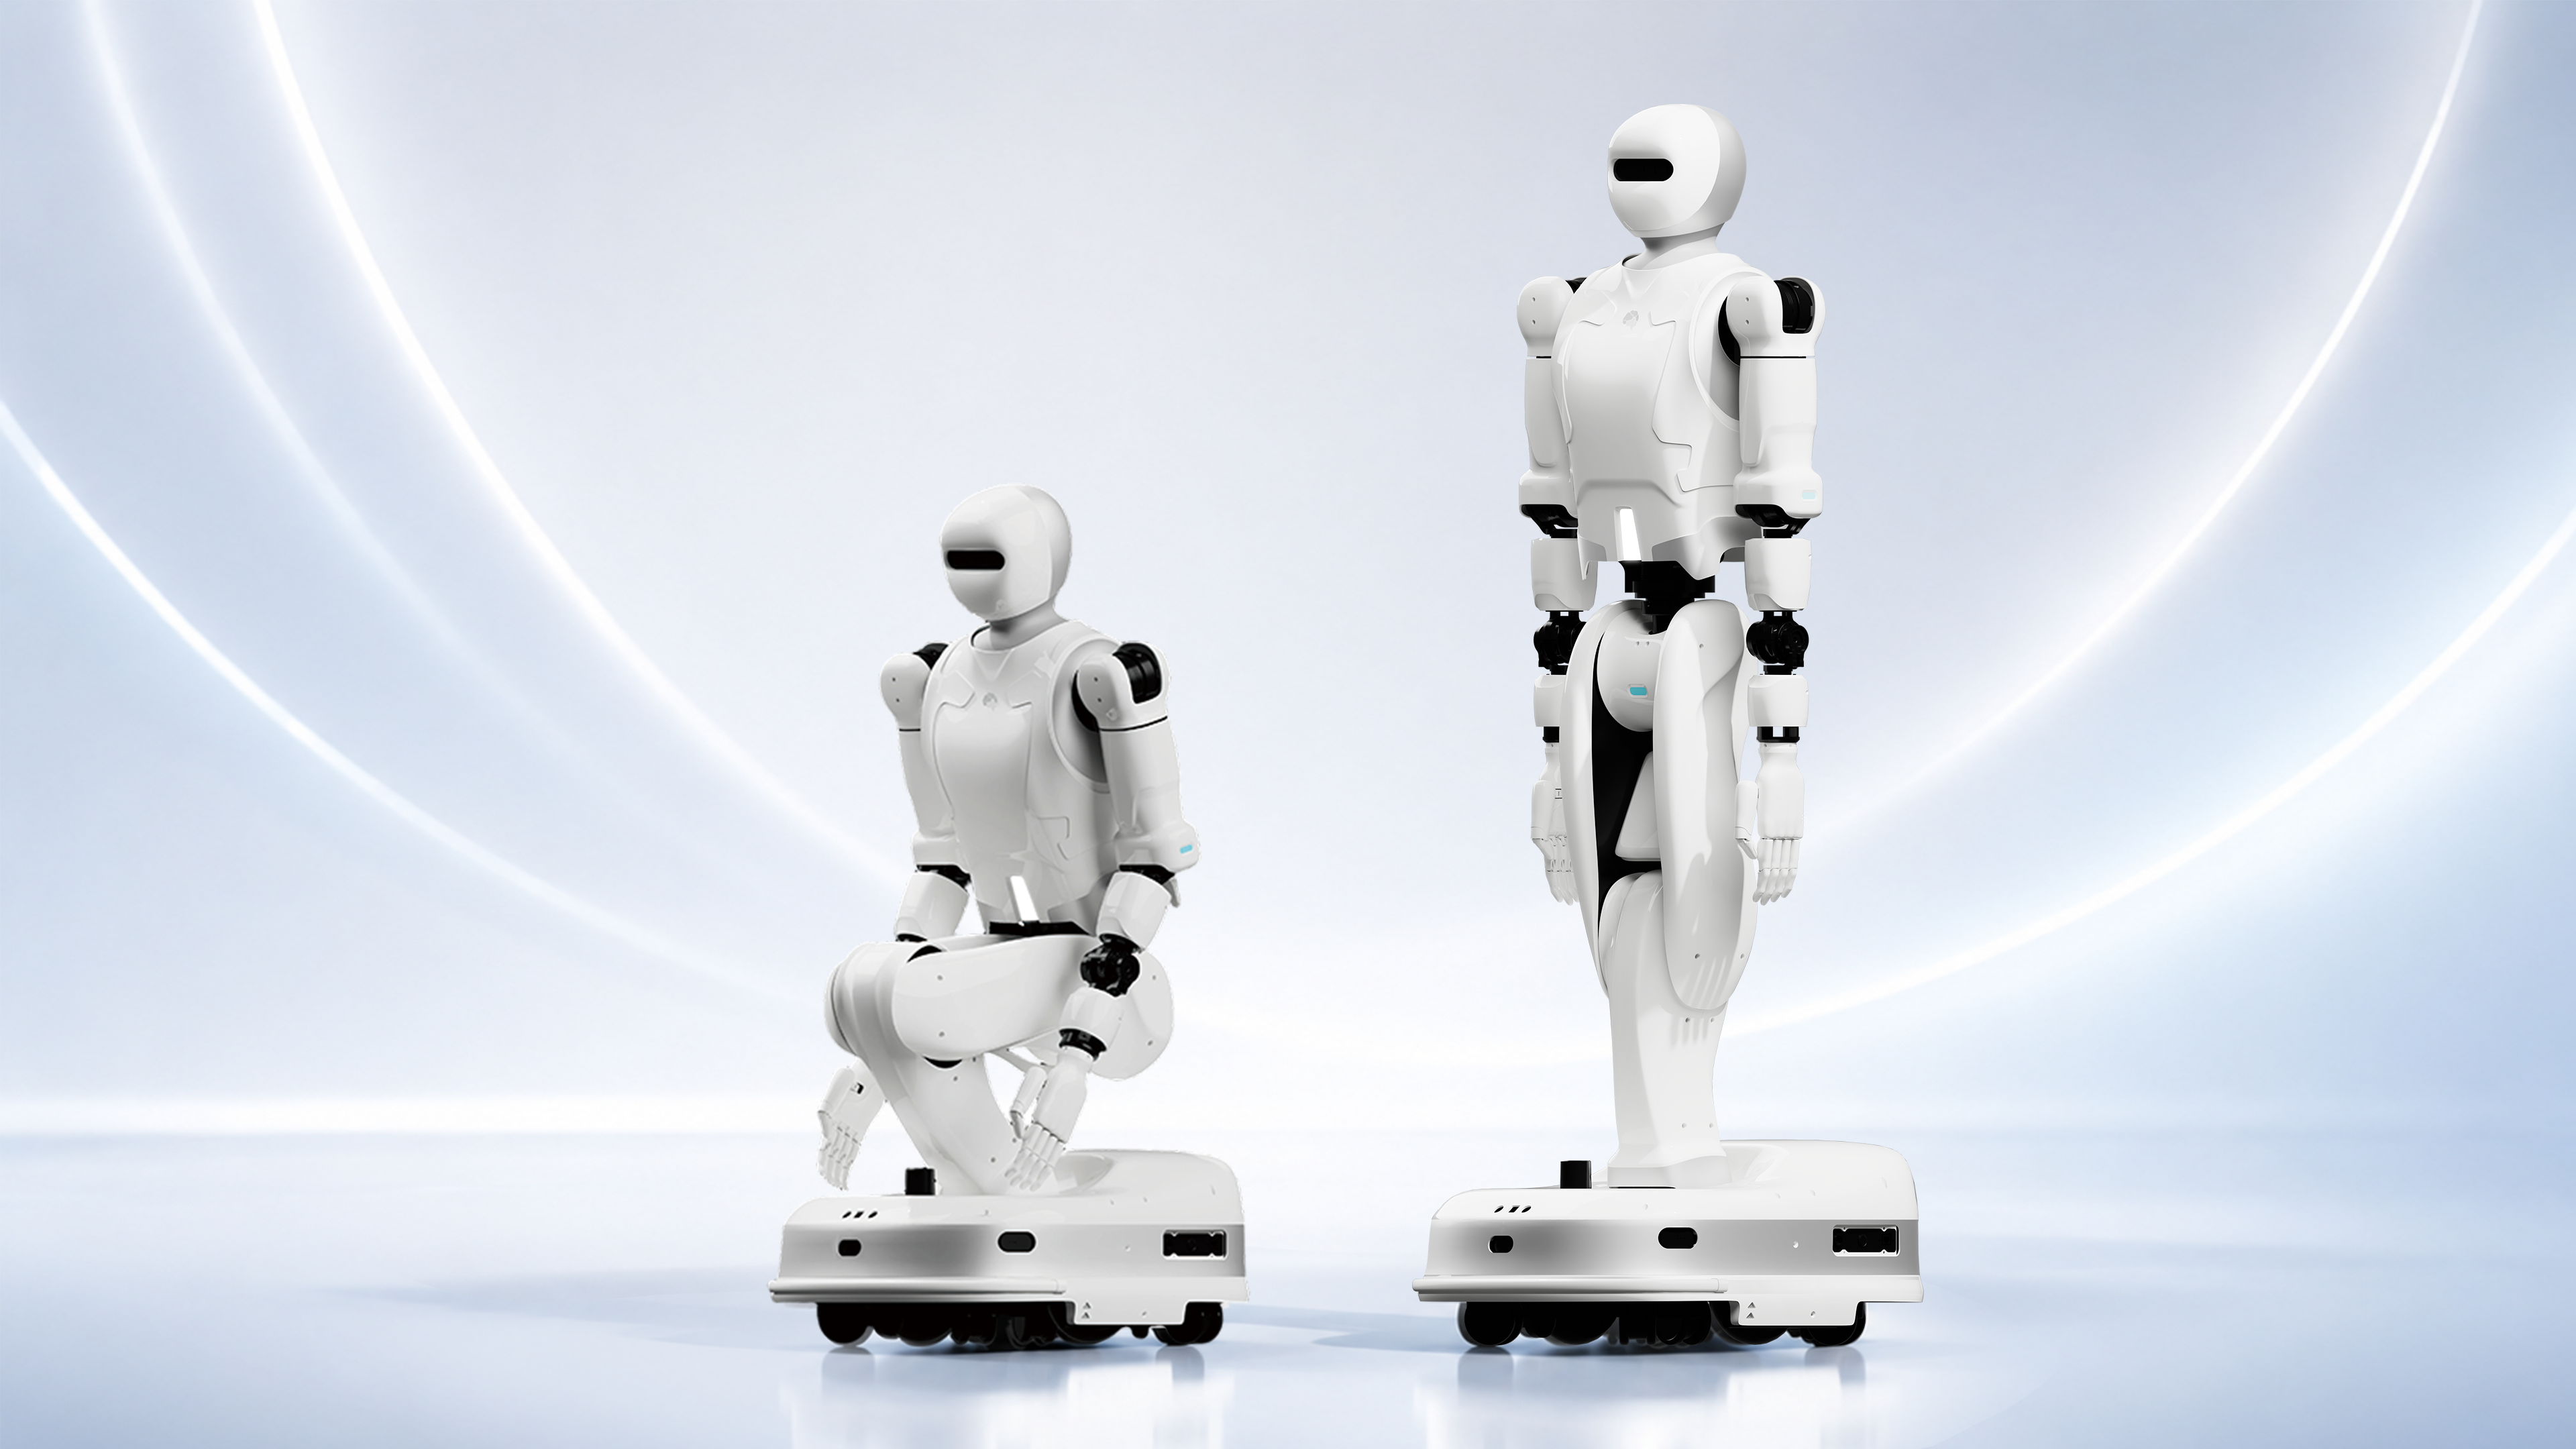
YMBot D
D 型工业款底盘人形机器人
Last updated: September 22, 2026

Locomotion Type
Wheeled
Stage
Pilot Delivery
Height
165 cm
Degrees of Freedom
22 DOF
Hand DOF
6 DOF
Weight
100 kg
Max Speed
5.4 km/h
Dual-Arm Payload
10 kg
Battery Life
8 h
Release Year
2026
Computing
Intel 12th-gen CPU
Product Overview
Wheeled-base industrial humanoid with mapping and autonomous navigation capability Dual 7-DOF arms (shoulder 3 + elbow 1 + wrist 3) with dual dexterous hands (6 DOF per hand, 12 joints, 540 g, thumb grip force 15 N) Supports VR teleoperation and inertial motion-capture teleoperation Folds from ≤600×600×1650 mm to ≤600×600×1100 mm for transport 220 Nm peak joint torque, 45 Ah battery, rear docking port with auto return-to-dock charging, RJ45 port for secondary development
Key Highlights
Wheeled-base industrial humanoid with mapping and autonomous navigation capability
Dual 7-DOF arms (shoulder 3 + elbow 1 + wrist 3) with dual dexterous hands (6 DOF per hand, 12 joints, 540 g, thumb grip force 15 N)
Supports VR teleoperation and inertial motion-capture teleoperation
Folds from ≤600×600×1650 mm to ≤600×600×1100 mm for transport
220 Nm peak joint torque, 45 Ah battery, rear docking port with auto return-to-dock charging, RJ45 port for secondary development
Application Scenarios
Industrial operation, data collection, security inspection, home service
Subscribe to Weekly Report
Get weekly updates on humanoid robot funding, new companies, and product launches.